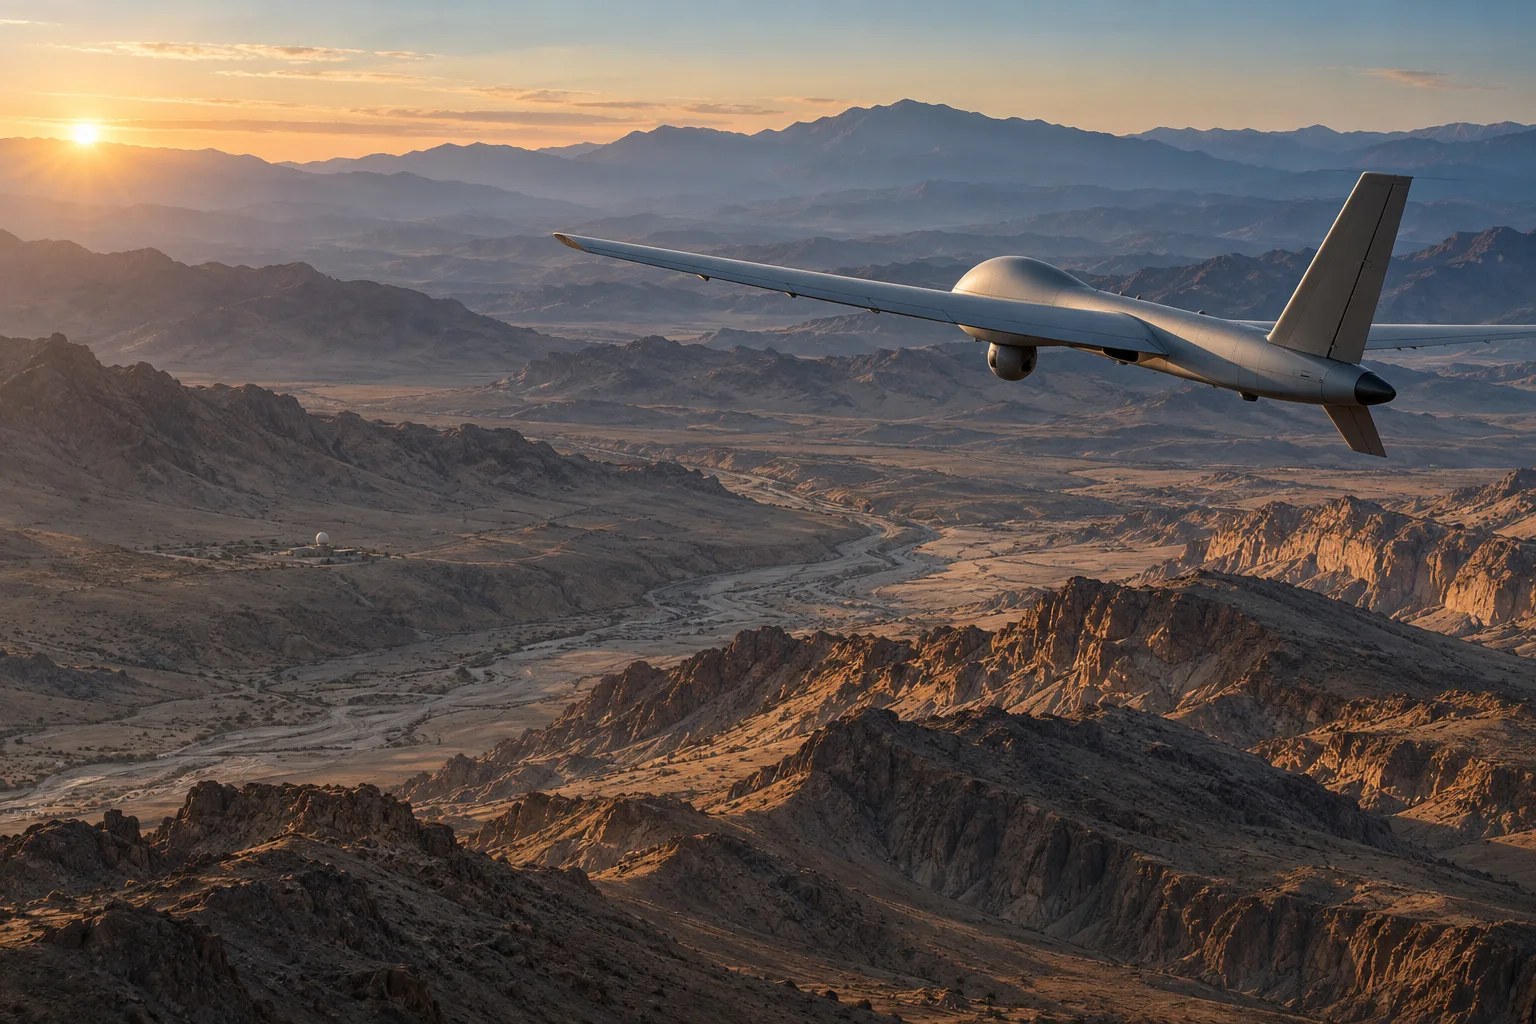
Defense observation
Support navigation and terrain observation during survey flights when satellite navigation is unreliable.
See terrain position fixesUSE CASES
Navigation and observation with radar, thermal and inertial sensing.
See the mission workflow
Support navigation and terrain observation during survey flights when satellite navigation is unreliable.
See terrain position fixes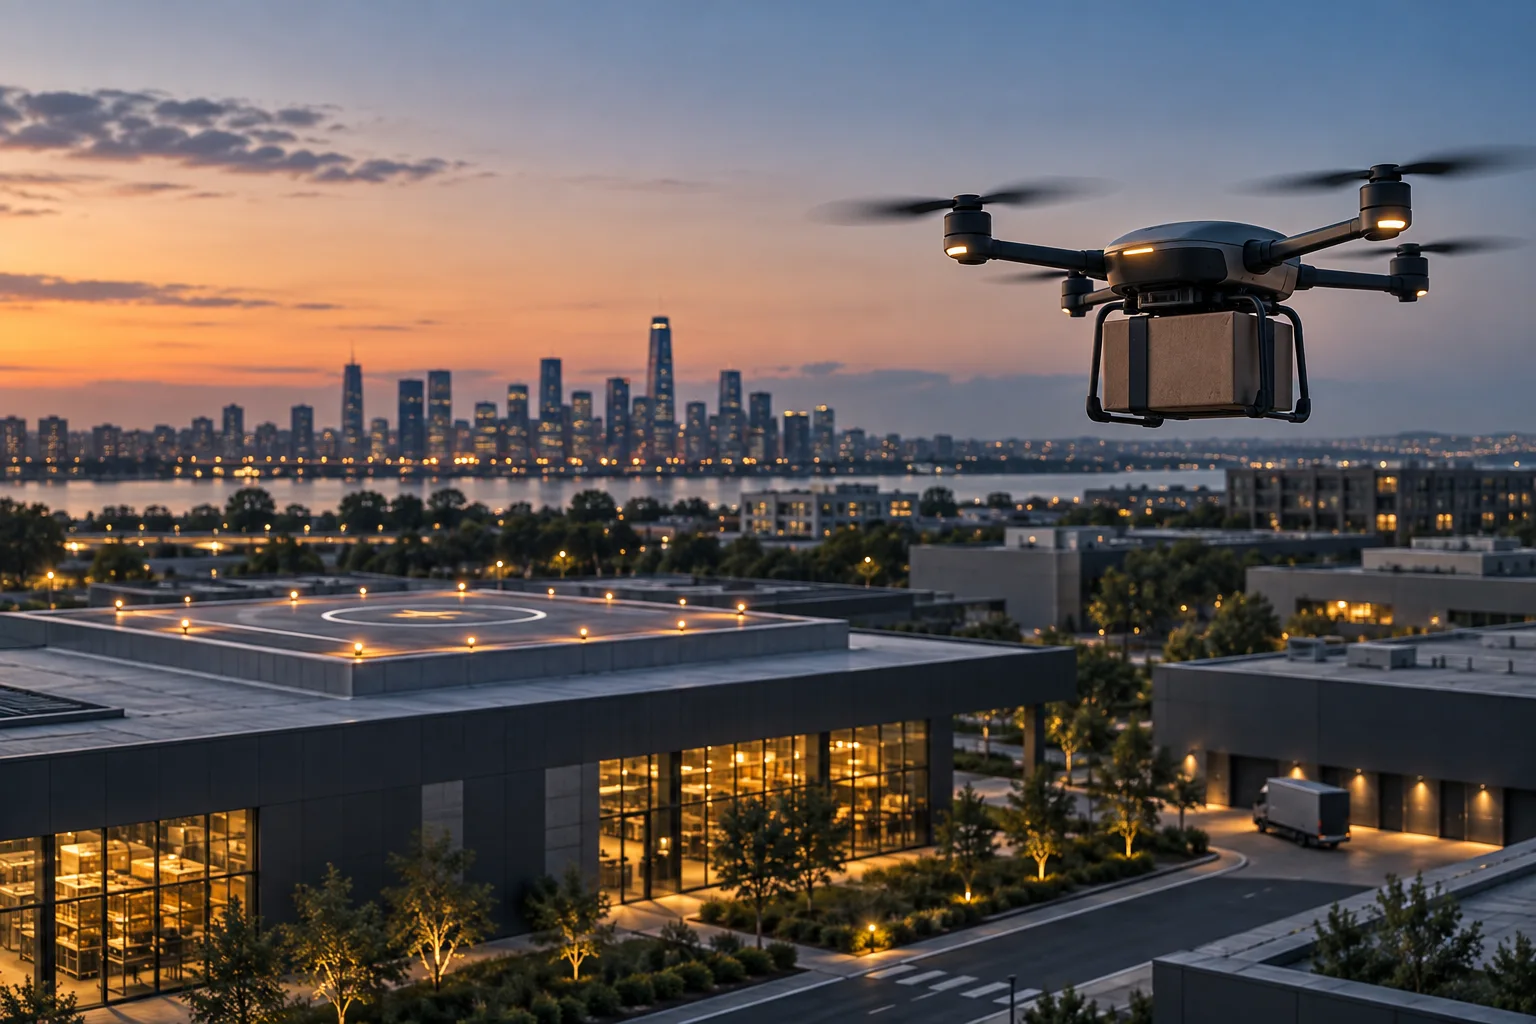
Carry the navigation estimate from pickup to delivery, using radar and checked scene references to constrain inertial drift.
See the mission workflow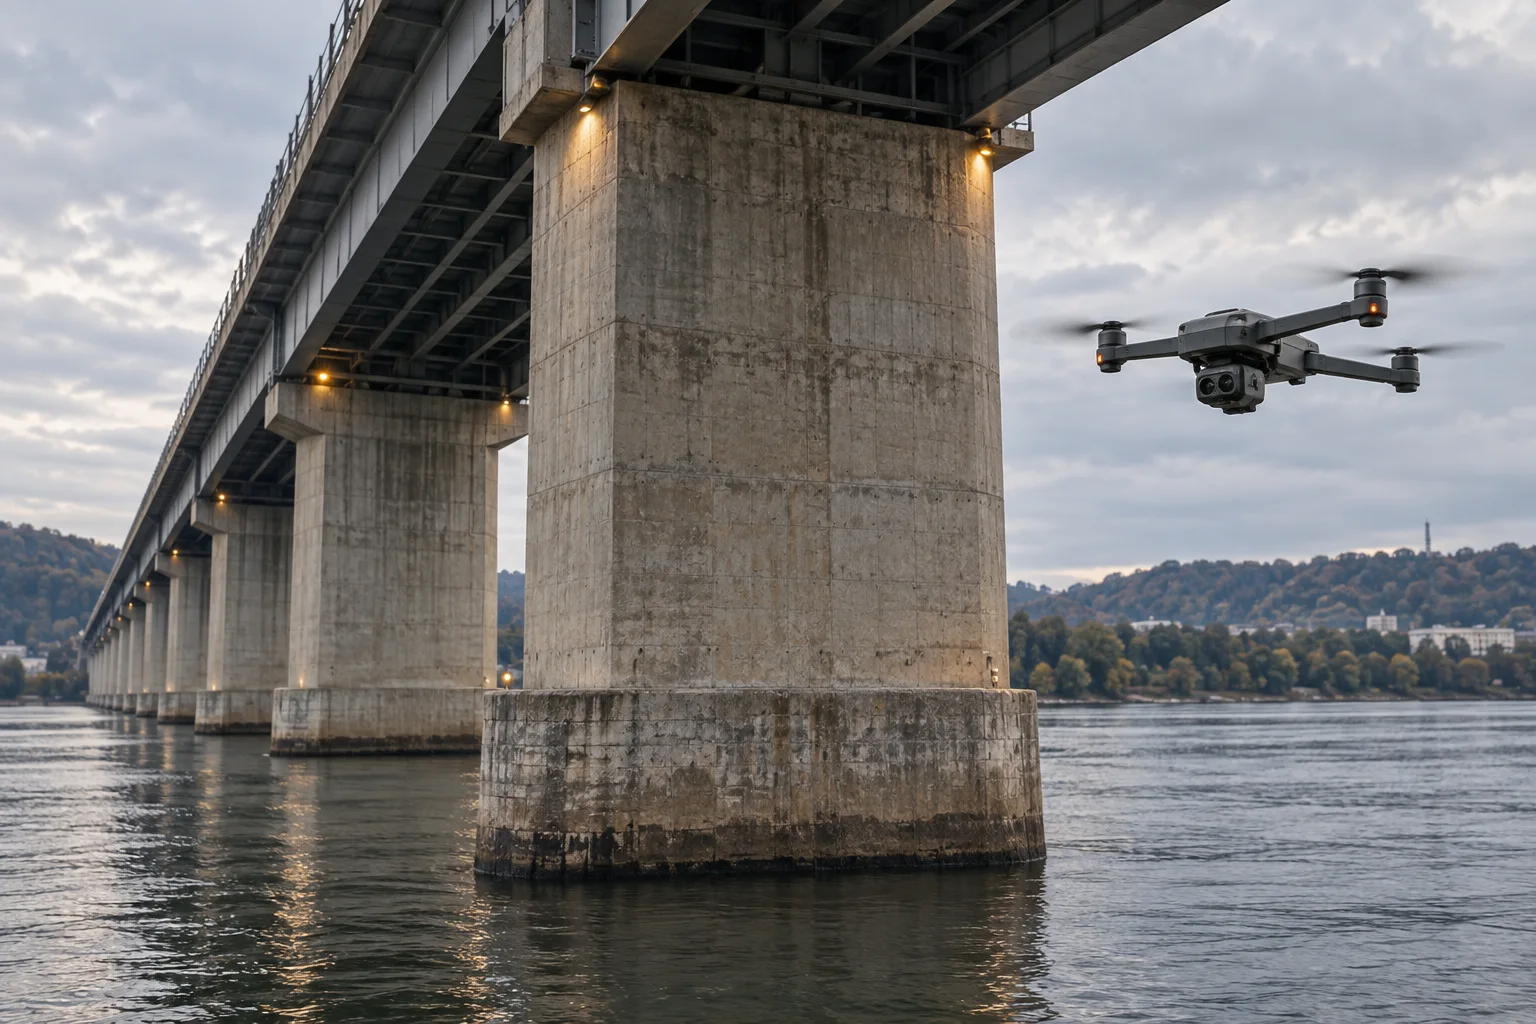
Relate thermal observations to structures while radar and inertial sensing constrain the aircraft’s motion estimate.
Discuss an inspection route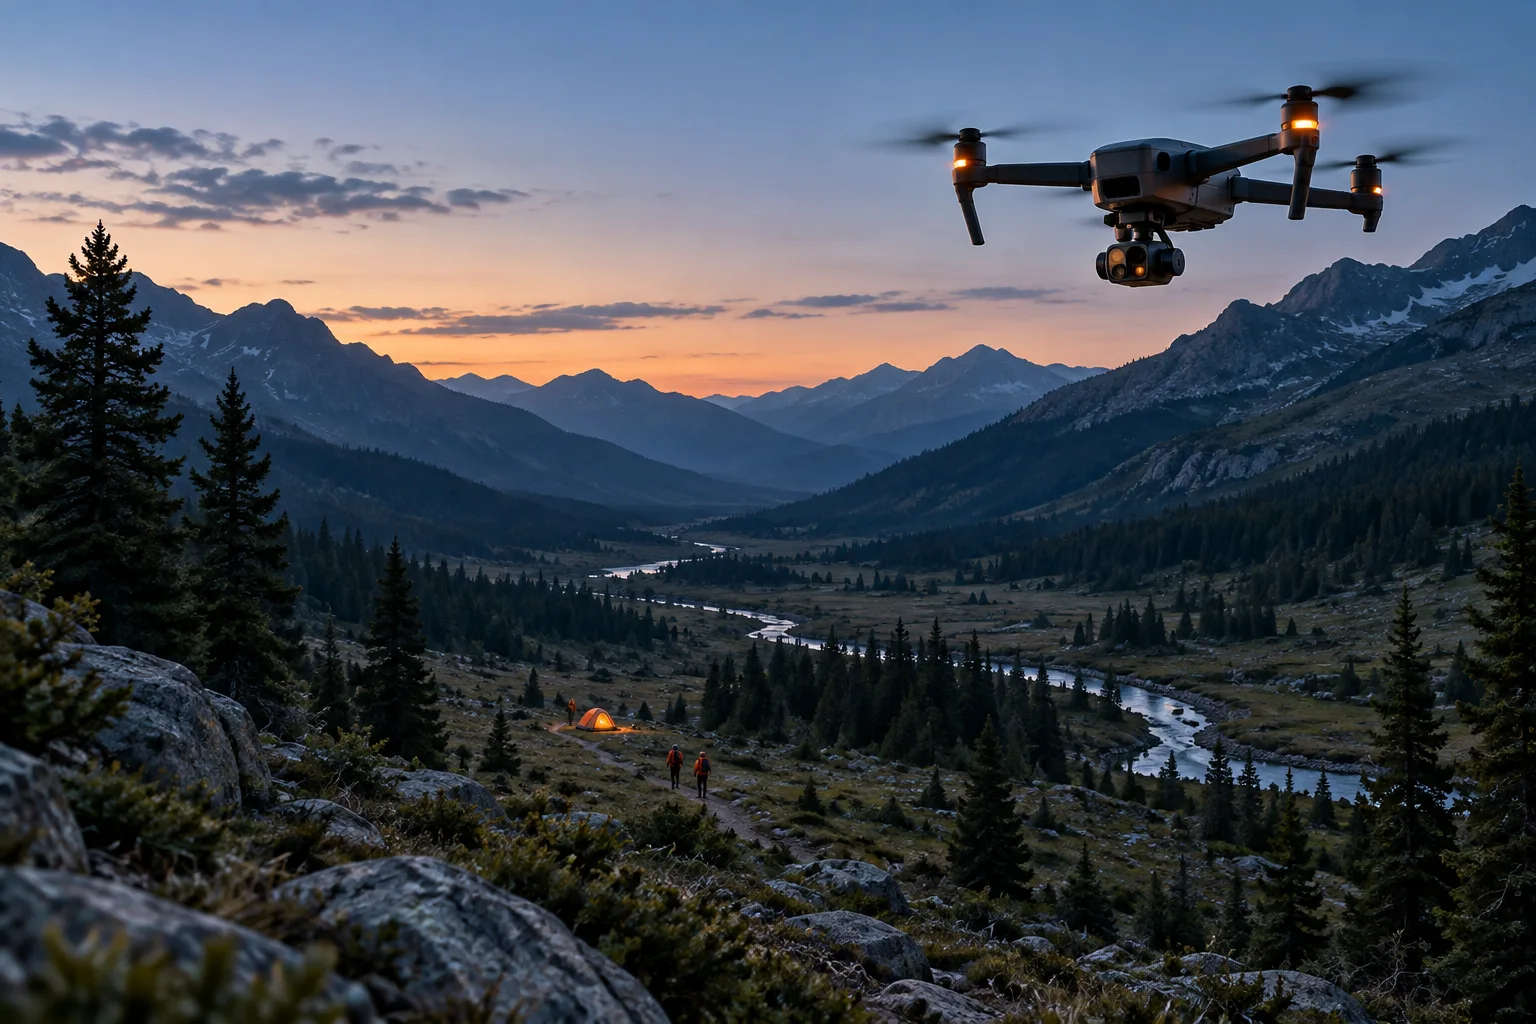
Review thermal cues during low-light searches, with navigation estimates to place observations for operator follow-up.
Discuss a search application
Keep observations aligned along planned survey passes using motion estimates and validated scene references.
See waypoint navigationProposed applications. Capabilities depend on integration and flight validation.
Concept illustration · generic units · state estimates and advisories only. No engagement logic or weapon effects.
Accept a scene match only when it agrees with the navigation estimate and independent observations.
Compare the observed patch with the reference.
AI-generated scene and scripted checks. The patch shares the reference image; this is not a live sensor match.
Concept illustration · generic units · state estimates and advisories only. No engagement logic or weapon effects.
Thermal acquisition supports selecting an object or location for operator review. Selection does not steer the aircraft. The replay uses synthetic observations.
Switch radar and thermal inputs to compare track estimates and uncertainty in a synthetic replay.
The interactive example could not load. The architecture explanation remains available below.
Loading the fusion example
Tracks
0 firm0 tentative0 coastingSeed 7 · reproducible replay
Concept illustration · generic units · state estimates and advisories only. No engagement logic or weapon effects.